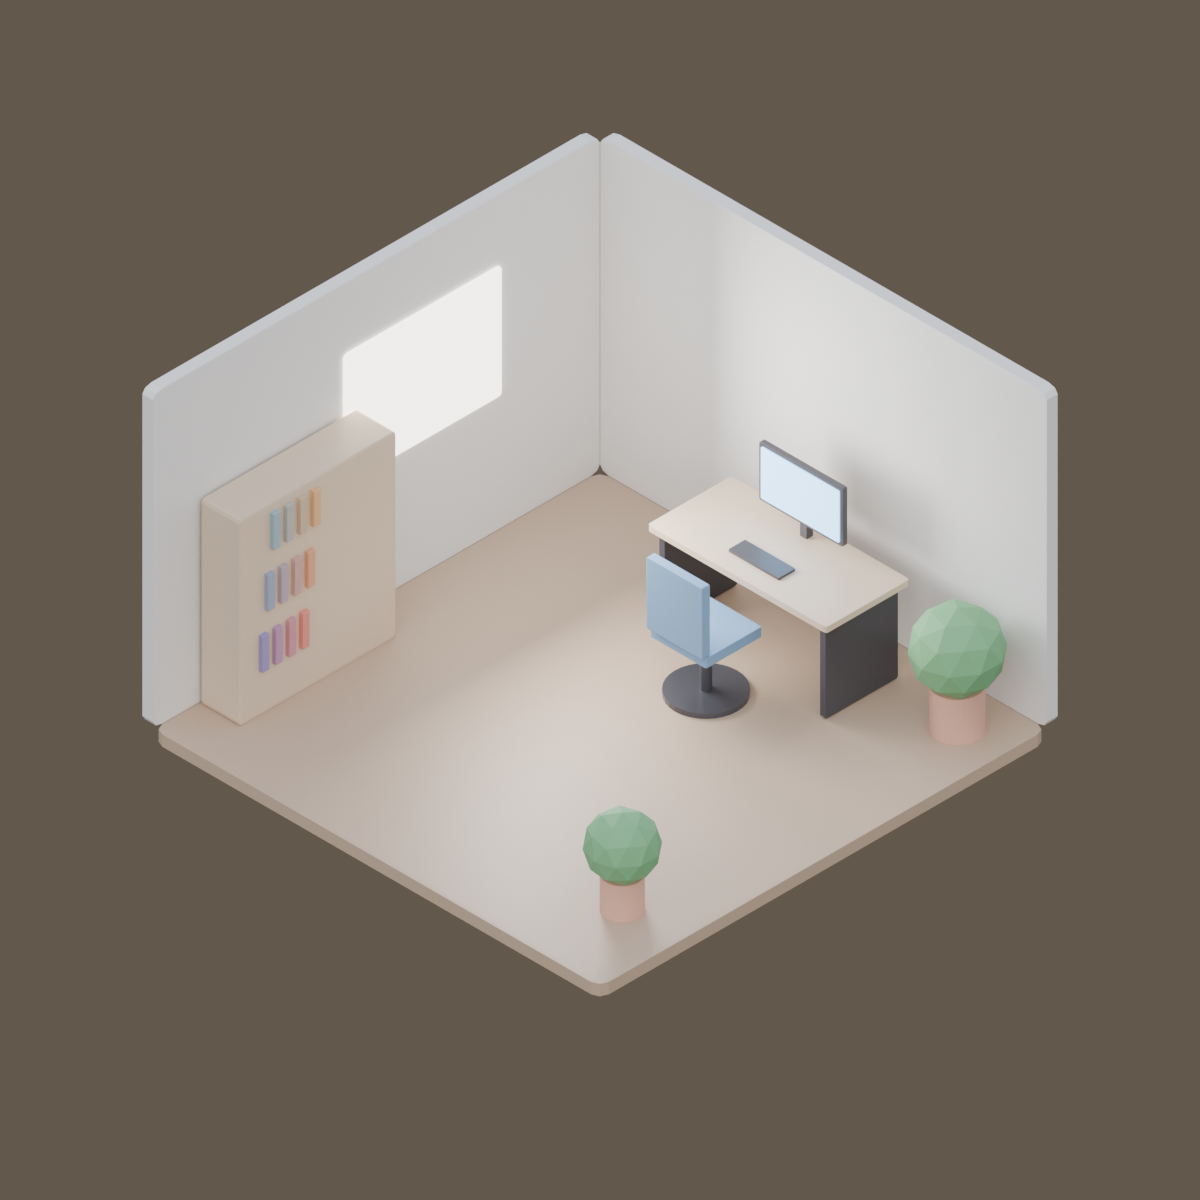
Render https://render.janction.jp/samples/ex25_isometric_office.py as a 1200x1200 still, 128 samples, overcast preset.
Reproducible JANCTION operator example. Source script and measured render settings are included; edit the script and render it again with your own key.
Rendered from benchmark run through JANCTION Render
| resolution | 1200 x 1200 |
|---|---|
| frames | 1 |
| samples | 128 |
| engine | Cycles / Blender 5.0 |
| lighting | overcast |
| GPU time | 3.67 s (GPU/CUDA) |
Try these settings on your own model
Browser only, no sign-up. The first preview needs no payment.
Render this script with your own key
Browser only, no sign-up. The first preview needs no payment.
"""JANCTION Render example 25: an isometric office corner with an orthographic camera (one still).

Reproduce: render_final(scene_url="https://render.janction.jp/samples/ex25_isometric_office.py",
                        width=1200, height=1200, samples=128, environment="overcast")
Two walls, a floor, a desk with a monitor, a chair, a shelf, plants and a bright window, all from cubes and
cylinders. The camera is orthographic at the classic isometric angles (54.7 and 45 degrees).
"""
import math

import bpy
from mathutils import Vector

for ob in list(bpy.data.objects):
    bpy.data.objects.remove(ob, do_unlink=True)
scene = bpy.context.scene
scene.frame_start = 1
scene.frame_end = 1


def material(name, color, roughness=0.6, emission=0.0):
    mat = bpy.data.materials.new(name)
    bsdf = mat.node_tree.nodes["Principled BSDF"]
    bsdf.inputs["Base Color"].default_value = (*color, 1.0)
    bsdf.inputs["Roughness"].default_value = roughness
    if emission:
        bsdf.inputs["Emission Color"].default_value = (*color, 1.0)
        bsdf.inputs["Emission Strength"].default_value = emission
    return mat


def box(name, size, location, mat, rotation=0.0):
    bpy.ops.mesh.primitive_cube_add(size=1, location=location)
    ob = bpy.context.active_object
    ob.name = name
    ob.scale = size
    ob.rotation_euler = (0, 0, rotation)
    ob.data.materials.append(mat)
    bev = ob.modifiers.new("Bevel", "BEVEL")
    bev.width = 0.02
    bev.segments = 2
    return ob


def cyl(name, radius, depth, location, mat, vertices=32):
    bpy.ops.mesh.primitive_cylinder_add(vertices=vertices, radius=radius, depth=depth, location=location)
    ob = bpy.context.active_object
    ob.name = name
    ob.data.materials.append(mat)
    return ob


wall = material("Wall", (0.86, 0.84, 0.8))
floor = material("Floor", (0.55, 0.4, 0.28), roughness=0.45)
wood = material("Desk", (0.72, 0.56, 0.4), roughness=0.4)
dark = material("Dark", (0.06, 0.06, 0.07), roughness=0.3)
screen = material("Screen", (0.35, 0.65, 1.0), emission=2.5)
fabric = material("Fabric", (0.2, 0.35, 0.55), roughness=0.8)
leaf = material("Leaf", (0.18, 0.45, 0.2), roughness=0.7)
pot = material("Pot", (0.75, 0.42, 0.3), roughness=0.5)
glow = material("Window", (1.0, 0.95, 0.85), emission=4.0)

box("Floor", (4, 4, 0.1), (0, 0, -0.05), floor)
box("WallBack", (4, 0.1, 2.6), (0, 2.05, 1.3), wall)
box("WallLeft", (0.1, 4, 2.6), (-2.05, 0, 1.3), wall)
box("Window", (0.02, 1.4, 1.0), (-1.99, 0.4, 1.55), glow)

box("DeskTop", (1.6, 0.75, 0.05), (0.2, 1.4, 0.75), wood)
for dx in (-0.72, 0.72):
    box("DeskLeg", (0.05, 0.65, 0.72), (0.2 + dx, 1.4, 0.37), dark)
box("Monitor", (0.75, 0.04, 0.45), (0.2, 1.62, 1.12), dark)
box("MonitorScreen", (0.7, 0.01, 0.4), (0.2, 1.595, 1.12), screen)
box("Stand", (0.06, 0.06, 0.2), (0.2, 1.65, 0.86), dark)
box("Keyboard", (0.45, 0.15, 0.02), (0.2, 1.25, 0.785), dark)

box("Seat", (0.5, 0.5, 0.08), (0.2, 0.75, 0.48), fabric)
box("Back", (0.5, 0.07, 0.55), (0.2, 0.5, 0.8), fabric)
cyl("ChairPost", 0.04, 0.42, (0.2, 0.75, 0.22), dark)
cyl("ChairBase", 0.28, 0.04, (0.2, 0.75, 0.02), dark)

box("Shelf", (0.35, 1.4, 1.6), (-1.8, -0.9, 0.8), wood)
for i, z in enumerate((0.35, 0.8, 1.25)):
    for j in range(4):
        box(f"Book{i}{j}", (0.22, 0.06, 0.28), (-1.7, -1.4 + j * 0.12 + i * 0.05, z + 0.14), material(f"Book{i}{j}", (0.3 + 0.15 * j, 0.25 + 0.1 * i, 0.5 - 0.1 * j)))

for k, (x, y, s) in enumerate(((1.6, 1.6, 1.0), (1.5, -1.3, 0.8))):
    cyl(f"Pot{k}", 0.18 * s, 0.35 * s, (x, y, 0.175 * s), pot)
    bpy.ops.mesh.primitive_ico_sphere_add(subdivisions=2, radius=0.32 * s, location=(x, y, 0.62 * s))
    bush = bpy.context.active_object
    bush.data.materials.append(leaf)

bpy.ops.object.light_add(type="AREA", location=(-1.0, 0.4, 1.6))
win = bpy.context.active_object
win.data.energy = 120
win.data.size = 1.2
win.rotation_euler = (0, math.radians(-90), 0)

# アイソメ: 部屋の中心から (1, -1, 1) の向きに離し、平行投影の幅を部屋の大きさに合わせる
center = Vector((0.0, 0.0, 1.0))
bpy.ops.object.camera_add(location=center + Vector((1.0, -1.0, 1.0)) * 12)
cam = bpy.context.active_object
cam.data.type = "ORTHO"
cam.data.ortho_scale = 7.6
cam.rotation_euler = (center - cam.location).to_track_quat("-Z", "Y").to_euler()
scene.camera = cam
ChatGPT · Claude · Grok · Perplexity
Use JANCTION Render (MCP server https://render.janction.jp/mcp) to make a render like this one: https://render.janction.jp/r/dkwissh3rq . First ask me what to change (my own model or scene, colors, camera), preview first, and ask me before the final render.
Each link opens the app with the text below filled in (if it is not, copy and paste it). If JANCTION Render is not connected in that app yet, add https://render.janction.jp/mcp as a connector first.
Rendered with JANCTION Render, a Blender render farm for AI agents (new keys start free). Render your own .blend or bpy script: see how to connect, or add the MCP URL https://render.janction.jp/mcp?src=share to Claude.ai, ChatGPT, Cursor or any MCP client. Report a problem with this page at the support page.
Was the result what you asked for?
Creators whose work is shown here may have received GPU credit from JasmyLab as thanks for publishing it. The amount does not depend on what they say, and their posts are not edited.
JANCTION Render v0.4.209 · JasmyLab Inc. · Updated 2026-10-26 · Tested with Blender 3.6 / 4.2 / 4.5 / 5.0 / 5.2, JANCTION Render 0.4.209 · 日本語